
A bridge designer needs to know how a structure will bend under traffic, wind, temperature changes, and its own weight. A battery engineer wants to predict heat buildup during rapid charging. An aerospace team may need to model airflow around a wing before building an expensive prototype.
In each case, the governing physics can be written as mathematics. The difficulty is that the resulting equations are usually too large, too coupled, or too irregular to solve exactly with pencil-and-paper methods.
That is where numerical methods enter engineering. They turn a physical problem into calculations a computer can perform, often millions or billions of them, to produce useful approximations within a practical time.
But “computable” is not the same as “efficient,” and “a result” is not automatically “a trustworthy result.” The real question is how numerical methods balance speed, memory, accuracy, stability, and engineering judgement.
🧭 What Numerical Methods Actually Do
Numerical methods are systematic procedures for approximating the solution of mathematical problems. Rather than finding an exact formula, they represent unknown quantities with numbers and repeatedly manipulate those numbers according to a defined algorithm.
For example, instead of solving the temperature at every point inside an engine component continuously, a program evaluates temperature at a finite set of locations. It then estimates how heat moves between neighbouring locations.
This approach is powerful because computers handle repeated arithmetic extremely well. Its limitation is equally fundamental: every numerical answer depends on choices about representation, algorithms, and computational resources.
🏗️ Why Large Engineering Problems Are Different
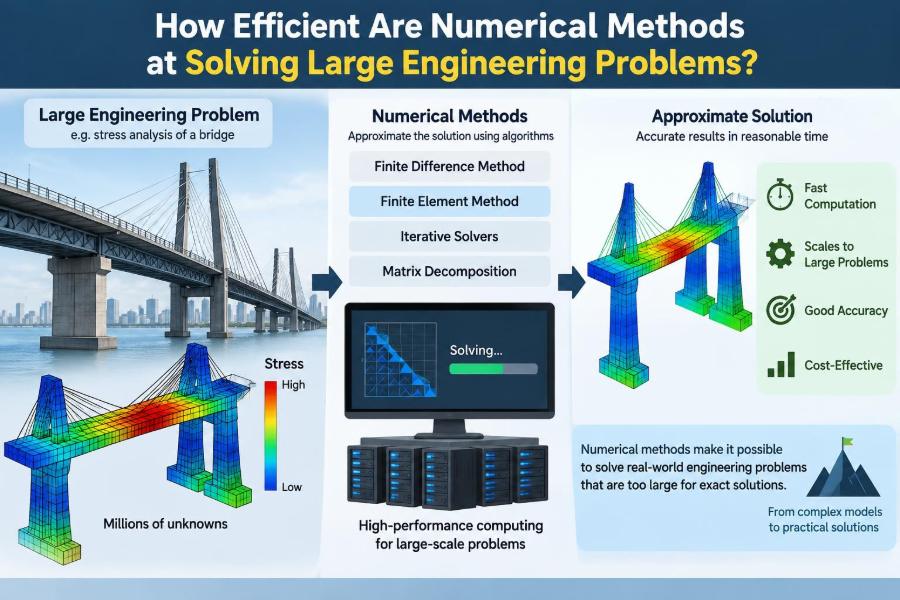
A small classroom problem may involve two unknowns and a neat set of equations. A realistic engineering model can involve millions of unknowns, several interacting physical processes, complicated material properties, and geometry with holes, joints, or moving parts.
Scale changes the nature of the task. A method that works perfectly for a small matrix may require too much memory or too much time once the model reaches industrial size.
Large problems also make small numerical weaknesses visible. A tiny error in a repeated calculation may remain harmless in a short computation but become significant after many time steps or iterations.
🧩 From Physical System to Discrete Model
Most numerical engineering begins with discretisation: replacing a continuous object, field, or process with a finite representation. A beam becomes segments, a fluid region becomes small cells, and time becomes a sequence of steps.
Finite difference, finite element, and finite volume methods are common ways to do this. Each describes the physical laws over small portions of a model and combines those local descriptions into a larger system.
Discretisation is not merely a programming detail. It determines what the simulation can resolve. If the mesh is too coarse near a sharp stress concentration or thin boundary layer, the model may miss the behaviour that matters most.
🔢 The Equations Behind the Simulation
After discretisation, many engineering problems take a form similar to Ax = b. Here, A represents known relationships in the model, x contains the unknown values, and b represents loads, sources, or boundary effects.
In structural analysis, the unknowns may be nodal displacements. In thermal analysis, they may be temperatures. In electrical networks, they may be voltages or currents.
The apparent simplicity of this notation hides the challenge. For a large model, A may have millions of rows. Choosing how to solve this system often dominates the total computational cost.
📏 Accuracy Is Not a Single Property
Engineers often ask whether a numerical result is accurate, but accuracy has several components. Discretisation error comes from replacing a continuous system with a finite mesh or time step. Round-off error comes from finite computer precision.
There can also be modelling error: the equations, material data, loads, or assumptions may not fully reflect the real system. A highly refined calculation cannot correct a poor physical model.
For this reason, an answer with many decimal places should not be mistaken for a highly certain prediction. Numerical precision and engineering accuracy are related, but they are not the same thing.
⚖️ The Core Trade-off: Cost Versus Resolution
Finer meshes and smaller time steps generally capture more detail. They also create more unknowns and more calculations. In three-dimensional models, reducing a typical cell size can increase the number of cells dramatically.
That growth affects memory, file size, setup time, solver time, and post-processing. It is why a model that runs in minutes at one resolution may run for hours or days at another.
Efficient modelling aims for sufficient resolution where the physics demands it, rather than maximum resolution everywhere. A local refinement near a crack tip or valve opening is often more valuable than uniformly shrinking the entire mesh.
🕸️ Mesh Quality Can Matter More Than Mesh Count
A mesh is the collection of elements or cells used to represent geometry. More elements can help, but poorly shaped elements may reduce accuracy and cause solver difficulties.
Highly stretched, skewed, inverted, or abruptly changing elements can distort numerical approximations. In fluid flow models, mesh quality near walls is especially consequential because velocity and temperature may change rapidly there.
A useful workflow examines both mesh density and mesh quality. Refinement should follow expected gradients, contact regions, curvature, and regions where engineering decisions depend on the result.
🧮 Direct Solvers: Reliable but Resource-Hungry
Direct methods solve a system through operations such as matrix factorisation. For suitable problems, they are robust and can provide highly accurate solutions without requiring an initial guess close to the answer.
The drawback is that factorisation can create many additional nonzero entries in memory, a phenomenon often called fill-in. For a very large three-dimensional model, this can make direct solution impractical on available hardware.
Direct solvers remain valuable for smaller systems, difficult ill-conditioned systems, and cases where reliability outweighs cost. They are also useful as benchmarks when assessing faster iterative approaches.
🔁 Iterative Solvers: Scalable but Conditional
Iterative methods start with an estimate and improve it repeatedly. Instead of fully factoring a matrix, they seek a solution through successive corrections until a chosen convergence criterion is met.
Methods such as conjugate gradient, GMRES, and multigrid-based schemes can be far more practical for large sparse systems. A sparse matrix contains mostly zeros, which is common when each mesh point interacts only with nearby points.
However, iterative methods are not automatically fast. Their performance depends on matrix properties, stopping criteria, scaling, mesh quality, and the quality of a preconditioner.
🛠️ Why Preconditioning Changes Solver Performance
A preconditioner transforms a linear system into one that is easier for an iterative method to solve. It does not alter the intended physical solution; it changes the numerical path used to reach it.
As an analogy, imagine climbing a steep, uneven hill while trying to reach a point at the top. Preconditioning reshapes the problem into a smoother route, so each step makes more consistent progress.
For many large simulations, preconditioner selection is one of the most consequential technical choices. A poorly chosen solver may stagnate, while a compatible preconditioner can reduce iterations substantially.
⏱️ Time-Stepping Controls Dynamic Simulations
Problems involving motion, vibration, heat transfer, chemical reactions, or transient flow must also decide how to advance time. The simulation calculates a state at one time level, then estimates the next.
Explicit schemes are often simple and can be efficient per step, but they may require extremely small time steps for stability. Implicit schemes can permit larger steps, but each step usually requires solving a larger algebraic system.
Neither approach is universally superior. Fast-impact simulations may suit explicit methods, while slowly evolving thermal or structural behaviour may justify the heavier work of an implicit method.
🚦 Stability Is a Requirement, Not a Bonus
A numerical method is stable when small errors do not grow uncontrollably as calculations proceed. Instability can produce oscillations, negative physical quantities, or values that increase without a plausible physical cause.
Stability restrictions may dictate maximum time steps or impose conditions on mesh spacing. These restrictions are mathematical properties of the method and the problem, not merely software warnings to bypass.
When a result behaves strangely, reducing the time step can be a useful diagnostic. But it is not a universal repair; incorrect boundary conditions, unsuitable formulations, or inconsistent units can create similar symptoms.
🎯 Convergence Does Not Prove Correctness
Solver convergence means an algorithm has met its internal stopping rule, often by making a residual sufficiently small. A residual measures how closely the current solution satisfies the discretised equations.
That is necessary, but it is not enough. A solution can converge cleanly for the wrong geometry, wrong material model, wrong load case, or insufficiently refined mesh.
Convergence answers “did the algorithm solve this numerical model?” Validation asks the more demanding question: “does this model represent the real engineering system well enough for its intended use?”
🔍 Verification and Validation Serve Different Purposes
Verification checks whether the mathematical model has been implemented and solved correctly. Typical checks include mesh-refinement studies, comparison with analytical cases, code tests, and conservation balances.
Validation compares model predictions with appropriate physical observations or experimental data when those are available. It examines whether assumptions and input data produce behaviour consistent with the actual system.
Both activities need context. A model validated for steady airflow over one geometry is not automatically validated for unsteady flow, different turbulence conditions, or a substantially altered design.
📉 Error Estimation Guides Smart Refinement
Refining every part of a model is expensive. Error estimation helps identify where refinement is likely to improve the quantity of interest, such as maximum stress, pressure drop, natural frequency, or heat flux.
A basic mesh-convergence study solves the problem on progressively finer meshes and observes whether key outputs settle toward a stable value. If the result keeps shifting materially, the model may not yet be adequately resolved.
Adaptive meshing automates part of this logic by concentrating elements where estimated error or solution gradients are large. It can improve efficiency, though it still requires careful interpretation and quality checks.
🧠 Nonlinear Problems Demand Extra Care
Many important engineering systems are nonlinear. Material stiffness may change with deformation, contact surfaces may open or close, fluid properties may depend on temperature, and turbulence models can introduce nonlinear couplings.
Nonlinear solvers usually proceed through iterations, updating the state until changes become acceptably small. The route to a solution can depend on initial conditions, load increments, damping, and algorithm settings.
A simulation that fails to converge is not automatically flawed; it may indicate a difficult but physically meaningful event such as buckling or contact transition. It can also signal an unsuitable setup, so diagnosis matters.
🌊 Coupled Physics Increases Both Value and Cost
Multiphysics models connect processes that influence one another: fluid flow and heat transfer, electromagnetic fields and structural forces, or chemical reactions and transport.
Coupling can be essential. For example, temperature changes may alter material properties, which changes stress, which can affect contact pressure and heat generation. Treating these effects separately may miss feedback that governs performance.
Yet coupled models are computationally demanding and more difficult to verify. A sensible engineering approach starts with the simplest model capable of addressing the decision, then adds coupling when evidence shows it matters.
💾 Memory Often Sets the Practical Limit
Processor speed receives attention, but memory capacity can be the first barrier in a large simulation. The program must store the mesh, field variables, matrix data, solver work arrays, and possibly many saved time states.
When a model exceeds available memory, the system may write temporary data to storage. This can slow computation sharply because storage access is much slower than memory access.
Efficient data structures, sparse storage formats, sensible output frequency, and domain decomposition can reduce memory pressure. Saving every variable at every time step is rarely necessary for an engineering decision.
⚙️ Parallel Computing Helps, but Not Perfectly
Large problems are commonly divided across several processor cores, graphics processors, or computing nodes. Each worker handles part of the calculations while exchanging information at boundaries.
This parallelism can reduce wall-clock time, but the speedup is rarely proportional to the number of processors. Communication, load imbalance, serial portions of the code, and memory bandwidth all limit scaling.
For example, doubling the number of processors may not halve runtime if each processor spends more time waiting for data. Efficient parallel models require partitions that are balanced and communicate as little as practical.
🖥️ Choosing Between CPU and GPU Computing
Central processing units are flexible and well suited to complex control logic, established solver libraries, and many general-purpose engineering workflows. Graphics processing units can perform large numbers of similar operations concurrently.
GPUs can be effective for highly parallel tasks, but transferring data between processor and GPU memory can reduce the benefit. Not all algorithms, material models, or software features map efficiently to GPU architectures.
The practical question is not which hardware is “best.” It is whether the solver and workload expose enough parallel work to justify the available architecture.
📊 Measuring Efficiency Beyond Runtime
A simulation that finishes quickly but gives an unreliable answer is not efficient in an engineering sense. Useful efficiency combines runtime with memory use, setup effort, robustness, accuracy for the target output, and the ability to repeat the workflow.
| Measure | What it reveals | Potential trap |
|---|---|---|
| Wall-clock time | How long a run takes | Can hide heavy hardware use |
| Iteration count | Solver difficulty | Each iteration may have different cost |
| Memory use | Whether a model fits hardware | May rise sharply during factorisation |
| Output stability | Whether refinement changes key results | Can miss local errors outside monitored outputs |
| Engineering turnaround | Time from question to decision | Depends on human workflow as well as computing |
For design work, turnaround is often decisive. A slightly less detailed model that supports several informed design iterations may be more useful than a perfect-looking result delivered after the decision window closes.
🏭 A Structural Analysis Example
Consider a hypothetical bracket supporting equipment in a machine. An engineer may first use a coarse finite element model to identify the load path and locate likely high-stress regions.
They can then refine the mesh around bolt holes, fillets, and contact zones rather than across the entire bracket. If material yielding or large deformation is relevant, a nonlinear analysis may be needed only after a linear model has clarified the main behaviour.
This staged process is efficient because it spends computational effort where it changes the design decision. It also makes errors easier to diagnose than starting immediately with a very large, opaque model.
✈️ A Fluid Dynamics Example
In computational fluid dynamics, a model of airflow through a duct may need enough near-wall resolution to estimate pressure loss and heat transfer. A coarse grid can capture the broad direction of flow while missing boundary-layer effects that control those quantities.
Increasing mesh density everywhere may be wasteful. Refinement is often focused near bends, sudden expansions, inlets, outlets, and walls, where gradients or separation are expected.
The selected turbulence model, inlet conditions, and convergence monitoring can matter as much as raw cell count. A visually smooth flow image is not sufficient evidence that pressure drop or heat-transfer predictions are reliable.
🔋 A Thermal Management Example
Thermal models are frequently used to assess electronics, motors, batteries, and buildings. Their efficiency depends on selecting suitable detail: a component-level network may answer an early design question, while a detailed three-dimensional model may be needed near a hotspot.
Transient thermal analysis adds another decision: how long the system must be simulated and what time resolution is needed. Very short steps may resolve rapid events but add cost without improving predictions of slow temperature changes.
Material interfaces deserve attention. Contact resistance and uncertain heat-transfer coefficients can contribute more uncertainty than a modest further increase in mesh density.
🧱 Model Reduction Makes Repeated Analysis Possible
Some applications need the same system evaluated many times: control design, optimisation, parameter studies, digital twins, or real-time monitoring. Solving a full high-fidelity model each time may be unrealistic.
Reduced-order models approximate the dominant behaviour using far fewer variables. They may be built from physical simplifications, previously computed solution patterns, or surrogate models trained on carefully selected simulations.
Reduction trades generality for speed. A reduced model can be excellent within its calibrated operating range but unreliable when conditions move far outside that range. Its limits must be documented, not assumed away.
🎲 Uncertainty Can Multiply Computational Work
Loads, dimensions, material properties, environmental conditions, and model parameters are often uncertain. Assessing their influence may require multiple simulations rather than a single nominal run.
A simple parameter sweep changes one or more inputs across plausible ranges. More advanced uncertainty methods may sample combinations of inputs or construct efficient approximations of the response.
Computational efficiency becomes especially important here because cost grows with the number of cases. Screening studies and reduced models can identify which uncertainties actually influence the output before launching a large campaign.
🧪 Benchmarking Must Resemble the Real Task
Software or hardware benchmarks can be useful, but a small demonstration problem does not necessarily predict performance on a production model. Real workloads may have different mesh types, nonlinear behaviour, input/output demands, and solver settings.
Meaningful benchmarking uses representative geometry, physics, mesh size, and accuracy targets. It records not only average runtime but also failed runs, memory limits, setup complexity, and repeatability.
Comparing settings fairly requires equivalent quality criteria. A solver that stops earlier may appear faster simply because it delivers a less converged answer.
⚠️ Common Ways Efficiency Is Lost
Many slow simulations are not limited by an unavoidable physical cost. They are slowed by setup choices that can be examined and improved.
- Using an unnecessarily fine mesh before establishing what output matters.
- Applying detailed physics where a simpler model would answer the current question.
- Using default solver settings without checking convergence behaviour.
- Saving excessive output fields or time histories.
- Running parameter studies before verifying a baseline model.
- Ignoring unit consistency, which can cause misleading scales and solver trouble.
- Changing several settings at once, making the source of improvement impossible to identify.
Efficiency work should be systematic. Measure a baseline, change one meaningful factor, and check that the engineering output remains acceptable.
🧰 A Practical Workflow for Large Models
Reliable speed usually comes from disciplined modelling rather than a single solver option. Begin by defining the decision the analysis must support and the quantities that control it.
- State the required outputs, load cases, and acceptable uncertainty.
- Build a simple model that captures the main physics.
- Check units, boundary conditions, material data, and conservation relationships.
- Perform mesh and time-step sensitivity checks on key outputs.
- Select a solver and preconditioner suited to the equation type.
- Refine locally, add nonlinearities, or couple physics only where justified.
- Document assumptions, convergence settings, and limitations for later review.
This workflow reduces wasted computation because it prevents teams from polishing a model before confirming that it addresses the right problem.
🧑🏫 Human Judgement Remains Part of the Solver
Numerical software can automate meshing, equation assembly, and iterative solution. It cannot independently decide whether a missing load case matters, whether a material law applies beyond a tested range, or whether a predicted failure mode is physically credible.
Experienced engineers use plots, balances, limiting cases, and simple hand calculations to challenge simulation output. These checks are not old-fashioned alternatives to computation; they are safeguards that give numerical work meaning.
The most productive question is often not “Can the computer solve this?” but “What is the least complicated model that can answer the engineering decision responsibly?”
🌟 The Core Principle: Fit the Method to the Decision
Numerical methods are remarkably efficient when they exploit structure: sparse interactions, appropriate discretisation, stable time integration, scalable solvers, and parallel hardware. They make many engineering questions tractable that would otherwise be inaccessible.
They become inefficient when detail is added without purpose, when accuracy is assumed rather than checked, or when computational metrics are separated from the real design objective.
The best numerical model is therefore not necessarily the largest or fastest one. It is the model that produces a verified, appropriately validated answer at a cost and timescale suitable for the decision being made.
Numerical methods solve large engineering problems efficiently when computational effort is directed by physics, accuracy requirements, and sound engineering judgement—not by model size alone. 📐⚙️🔍